
Desktop SCARA Robot Arm
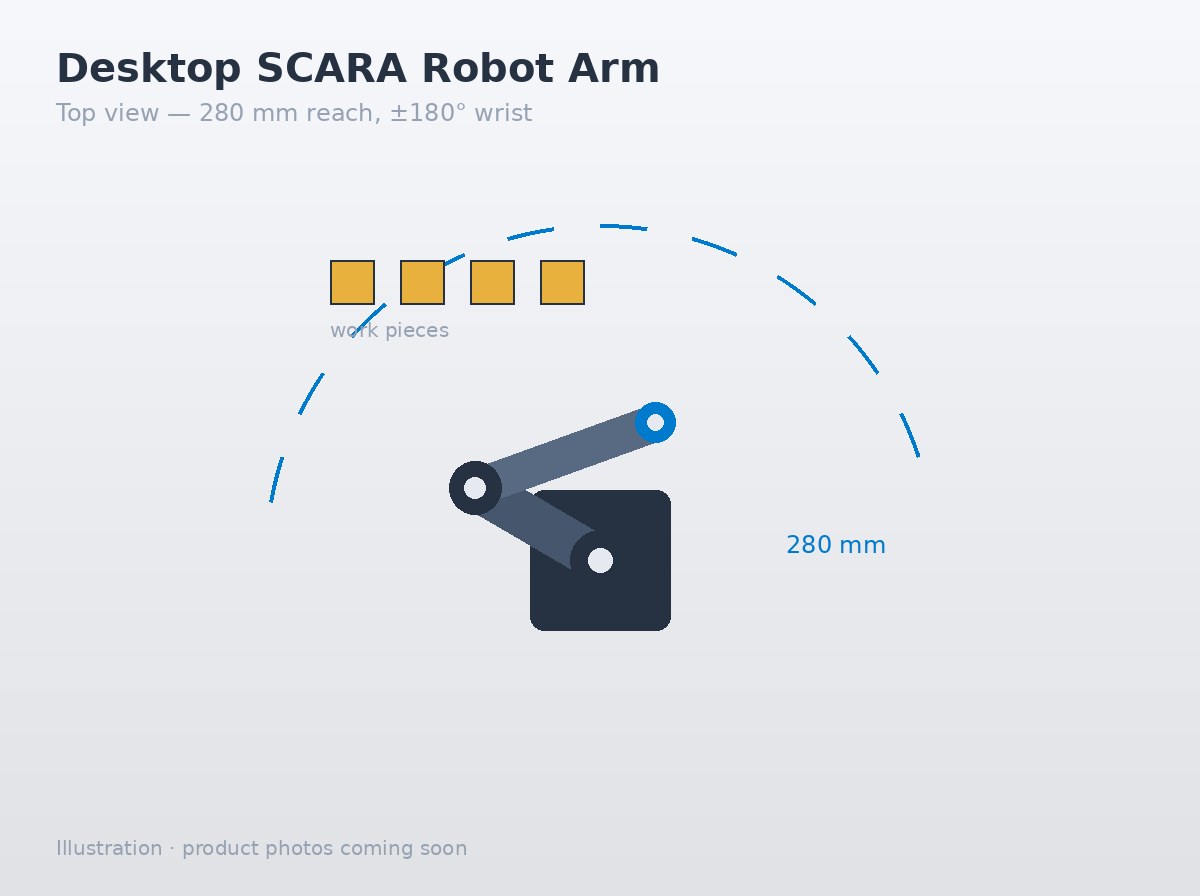
4-axis SCARA arm with ESP32 GCode controller — the same toolchain as our Delta robot, with a larger reach.
from $699.00
In stock
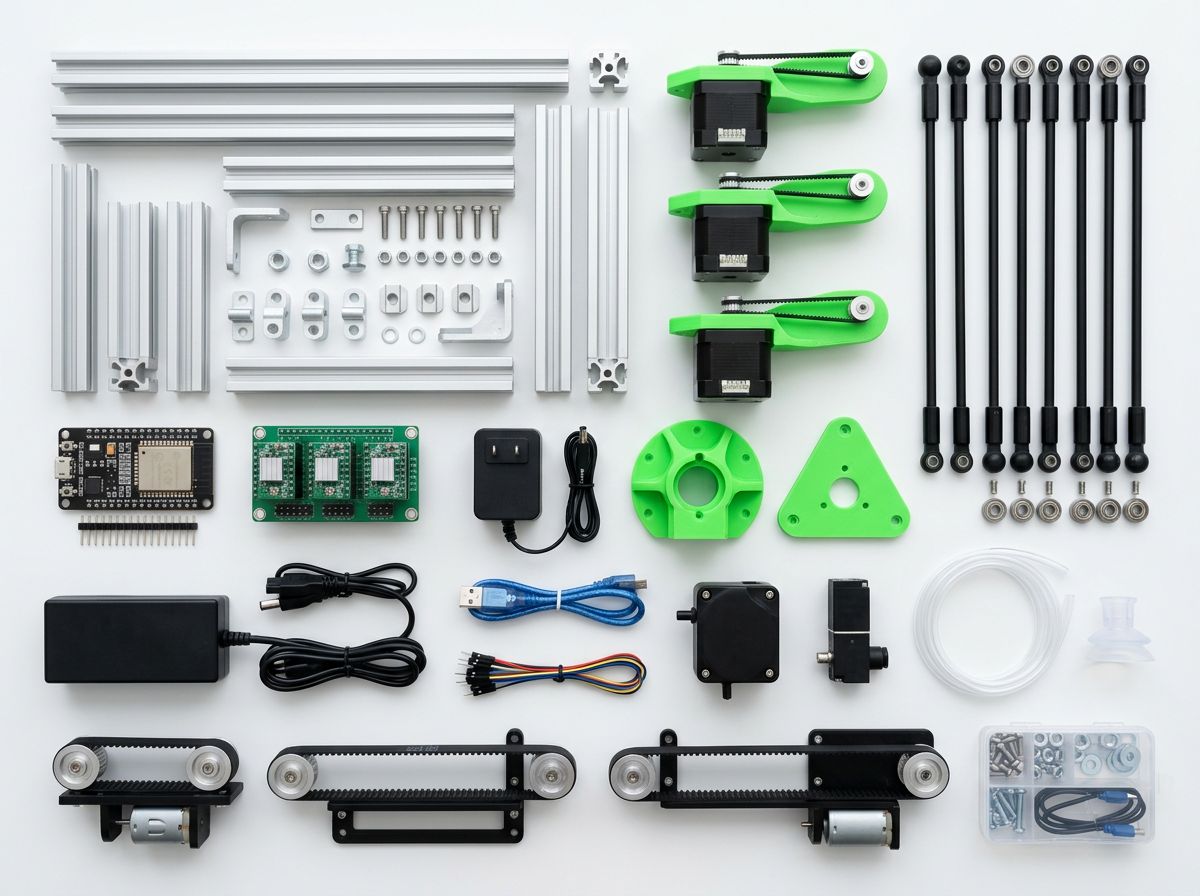
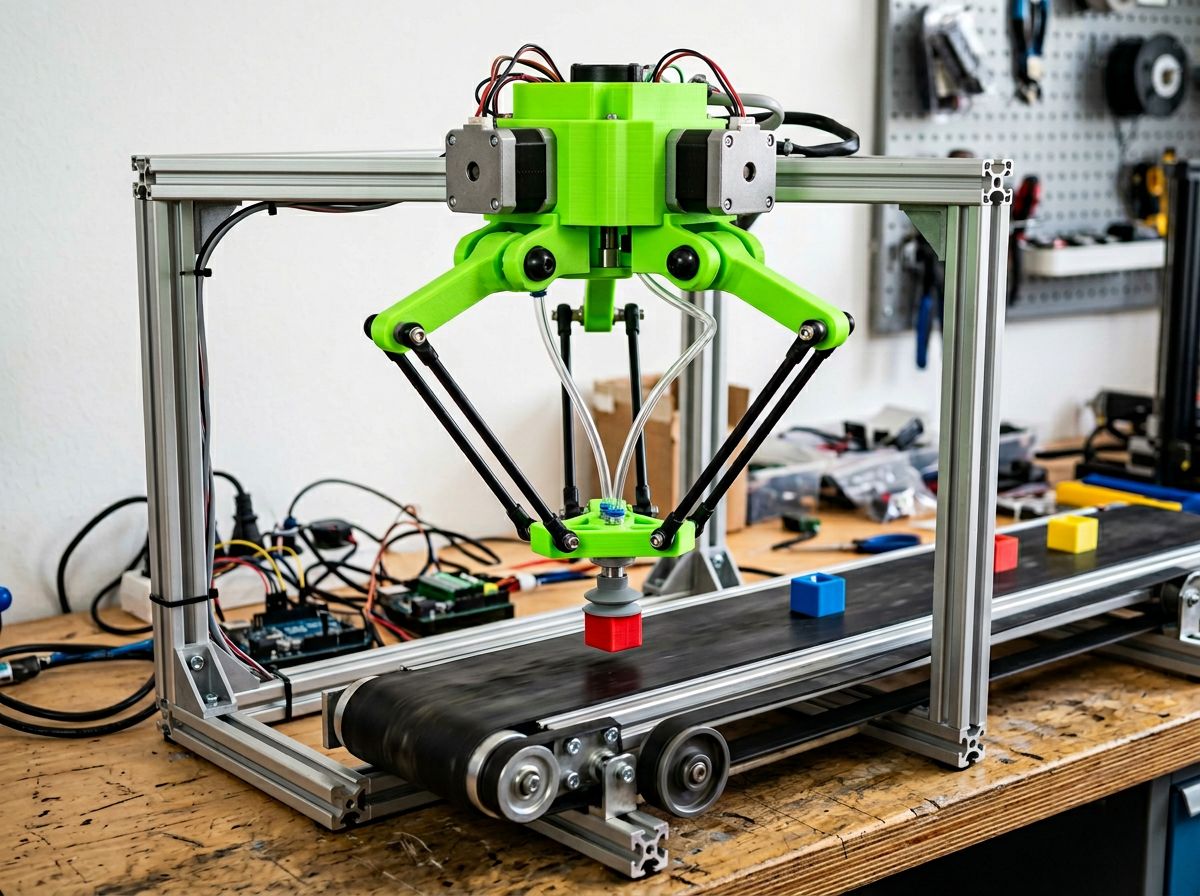
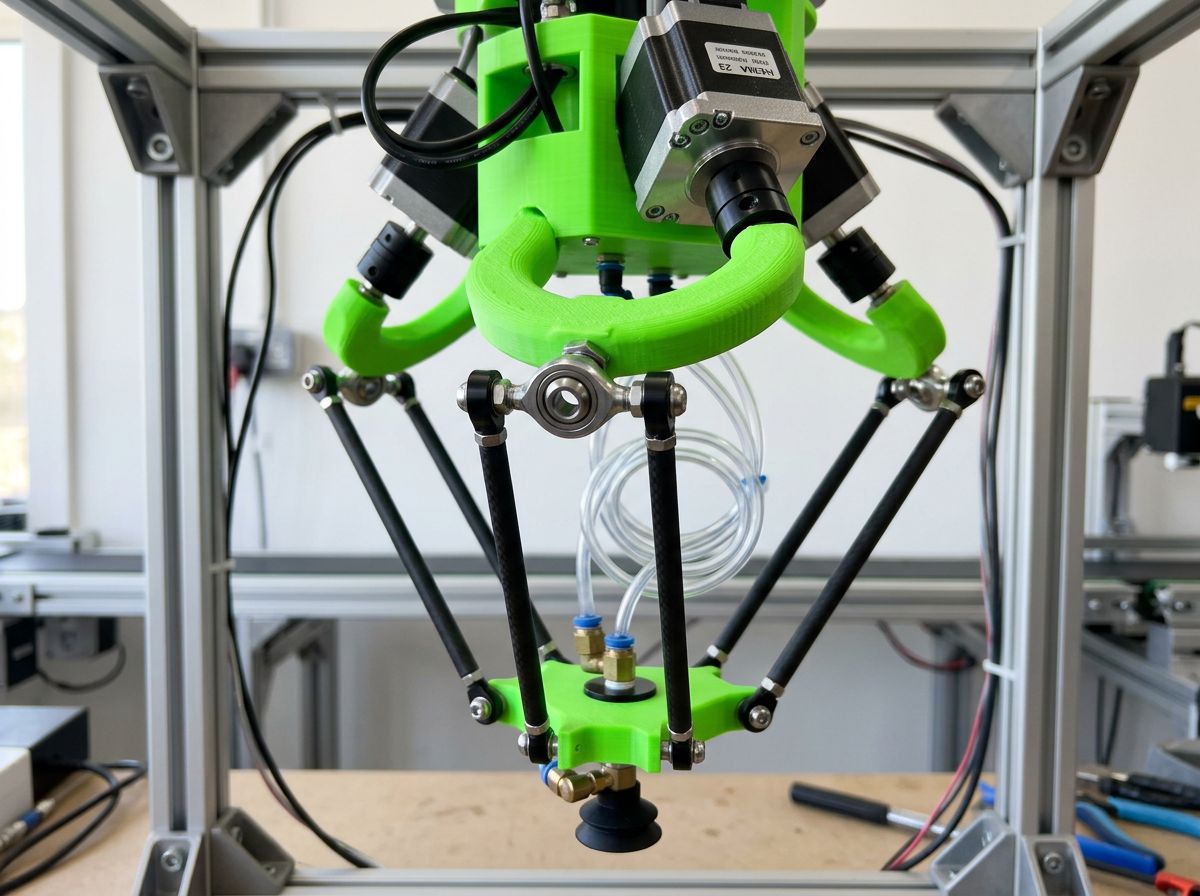
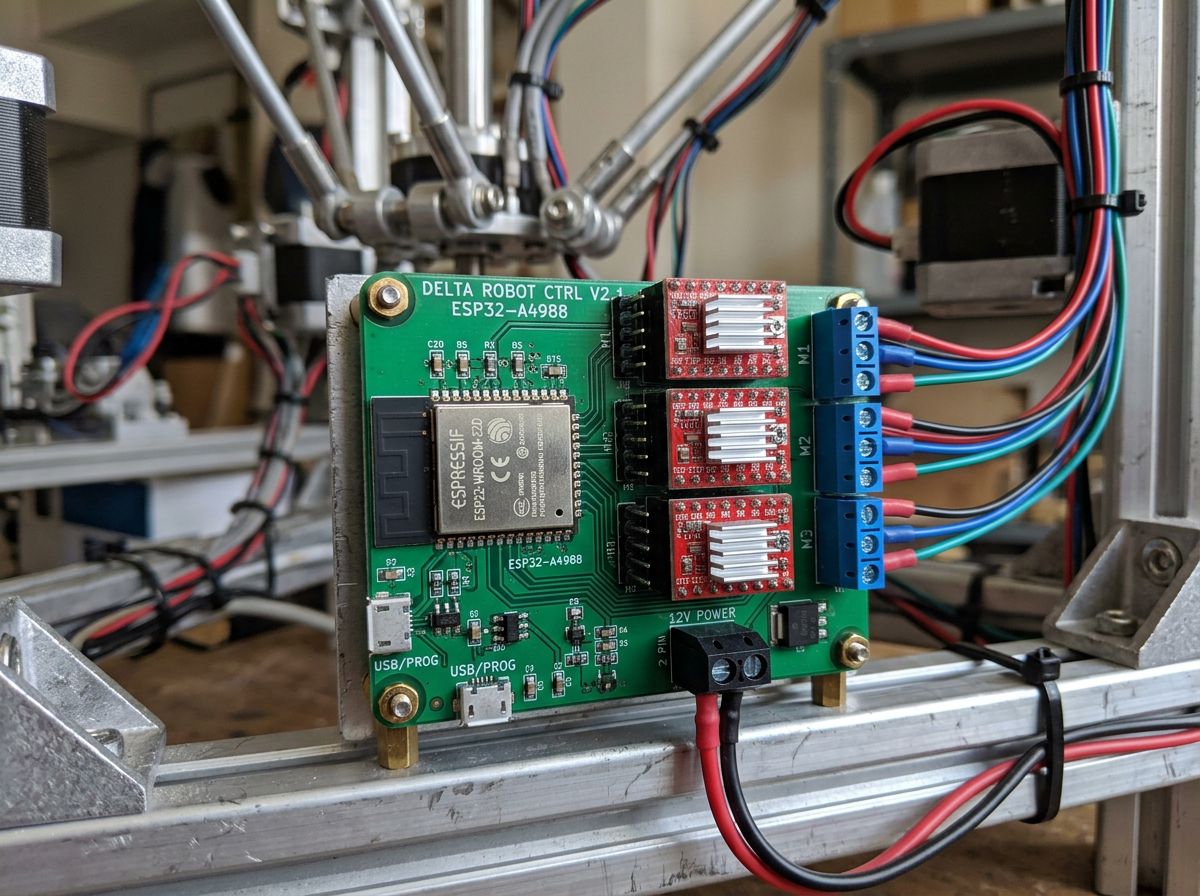
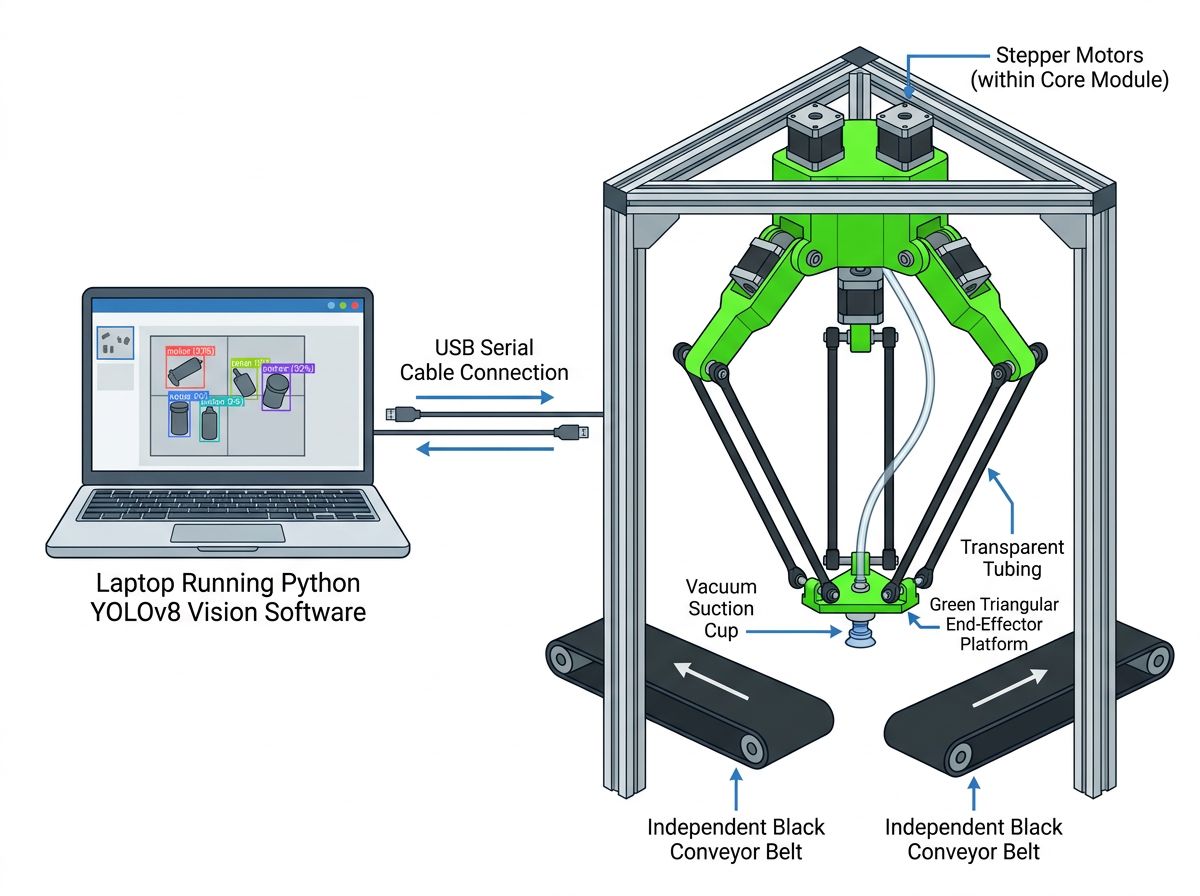
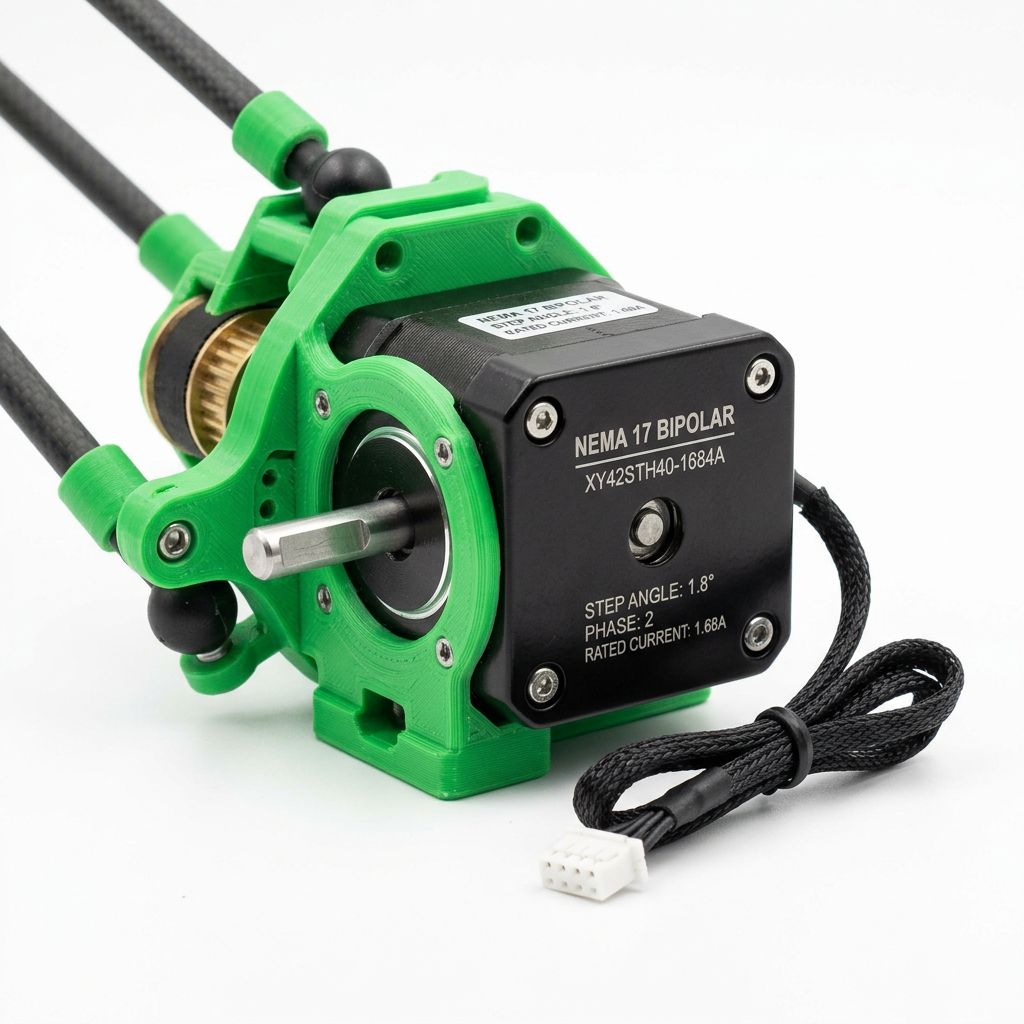
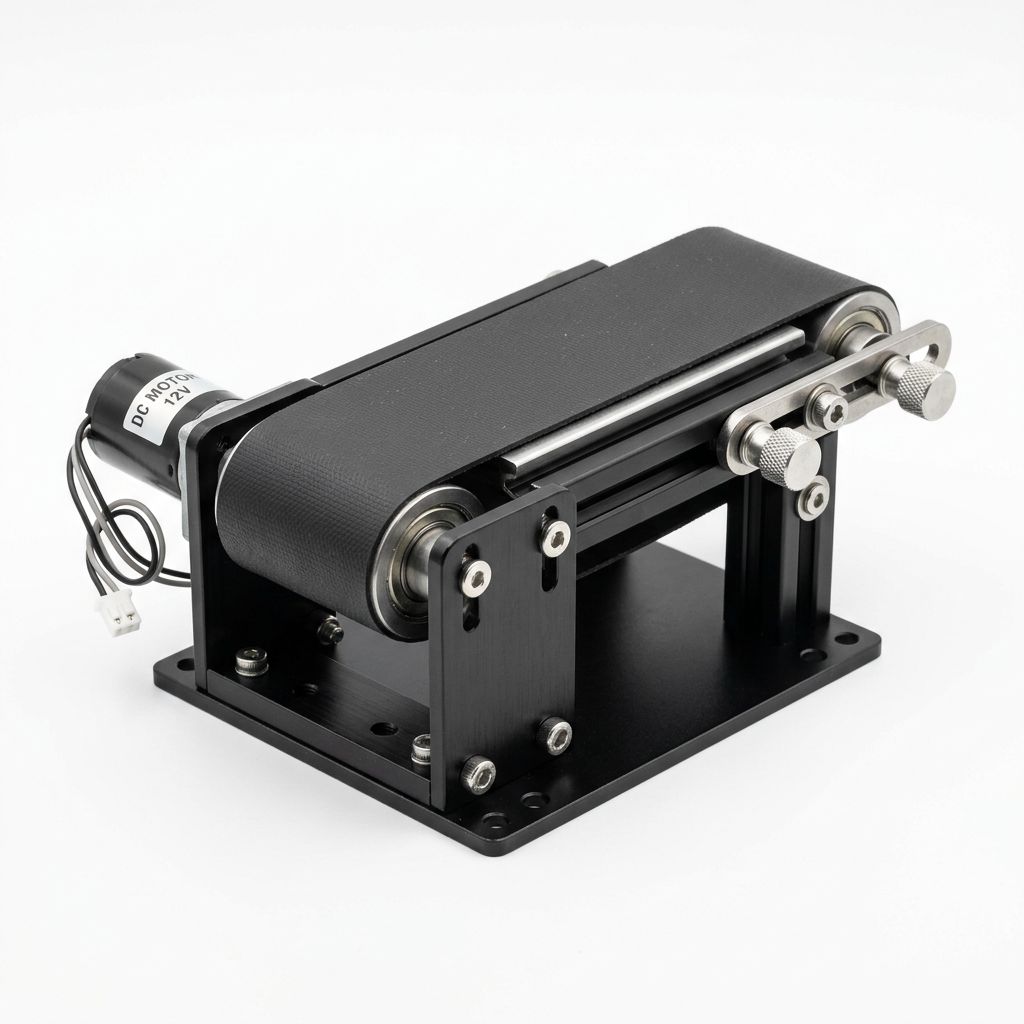
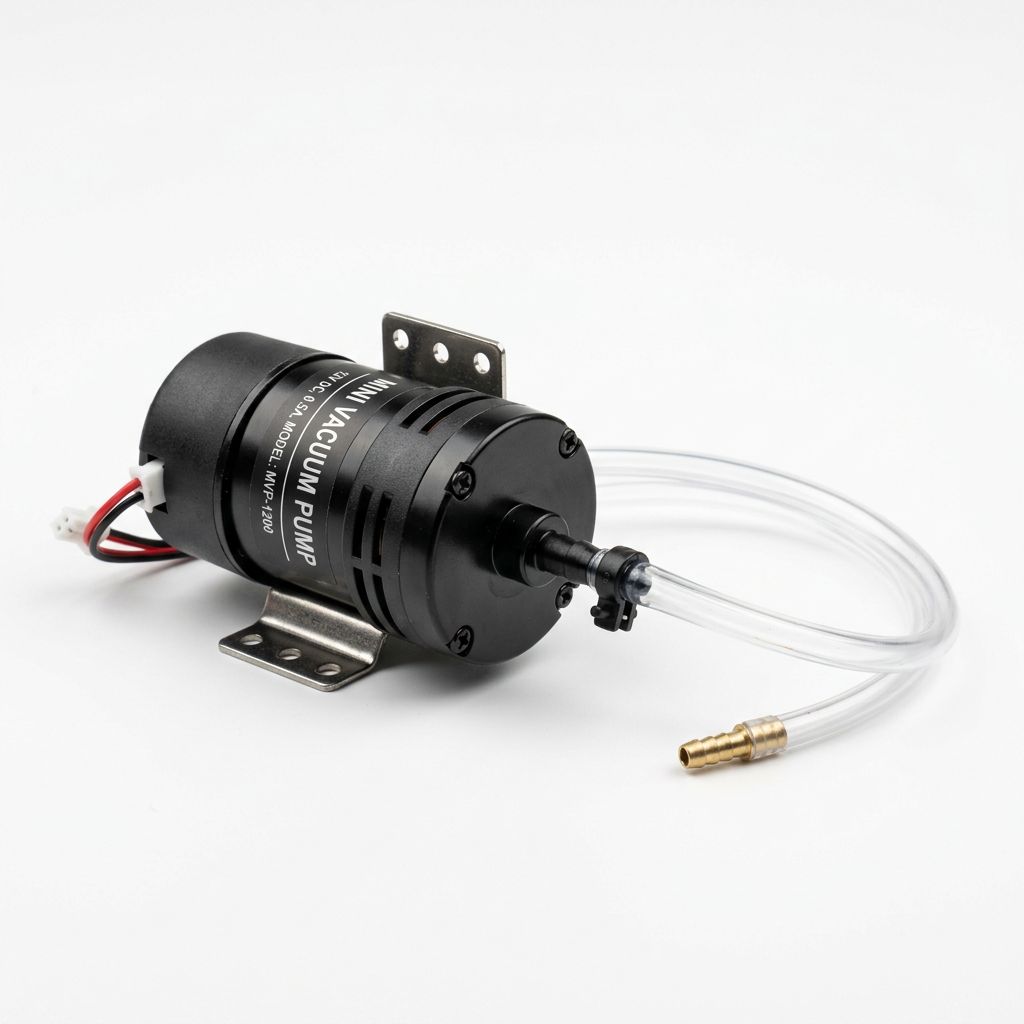
3-DOF delta robot with ESP32 control, vision and conveyor — assembled, documented and ready to program.
A complete delta parallel robot development platform: pre-assembled arm, ESP32 controller with GCode firmware, YOLOv8 vision, pneumatic pick-up and dual conveyors. Ships with 100+ pages of documentation.
| Type | Delta parallel robot (3-DOF) |
|---|---|
| Working Envelope | ~Ø200mm × 180mm (Z-axis, approximate) |
| Precision | ±0.1mm (typical) |
| Max Speed | 100mm/s |
| Payload | 200g (maximum) |
| Arm Lengths | Upper: 150mm / Lower: 281mm |
| End Effector Offset | 50mm |
| Frame Material | Aluminum extrusion (2020) |
| Controller | ESP32-D0WDQ6 (240MHz dual-core) |
|---|---|
| Motors | 3× NEMA17 (1.8°, 200 steps/rev) |
| Microstepping | 16 microsteps (configurable) |
| Gear Ratio | 4.5:1 (optimized for precision) |
| Drivers | A4988 or DRV8825 compatible |
| Communication | USB Serial (115200 baud) |
| Power Supply | 12V DC, 3A (36W) |
| Limit Switches | 3-axis endstop support |
| Vision System | YOLOv8 (pre-trained model included) |
|---|---|
| PC Software | Python 3.10 + PySide6 + OpenCV |
| Firmware | Arduino C++ (ESP32 core) |
| Protocol | Standard GCode (G0/G1/G28/M-codes) |
| Kinematics | Real-time inverse kinematics solver |
| Interpolation | Cosine acceleration profile |
| Platform | Windows 10/11 (Linux compatible) |
| Command Queue | 10-command buffer (configurable) |
| Pneumatic System | 12V vacuum pump + PWM solenoid valve |
|---|---|
| Conveyor Belt | Variable speed (200-1000Hz) |
| Camera | USB camera (640×480, 30fps) |
| End Effector | Suction cup (Ø20mm) |
| Wiring | Pre-crimped JST connectors |
| Documentation | 100+ pages (PDF + online wiki) |
| Examples | Pick & place, sorting, calibration |
| Support | Email support (service@nenpower.com) |
Quick Start
Understand the Delta robot and complete your first run in 30 minutes: system architecture, use cases, hardware connecti…
Hardware
2–3 hours, intermediate: kit checklist, tools, assembling the base, motors, arms, end effector and pneumatics, ESP32 pi…
Software
1 hour, easy: Python 3.10 environment, dependencies, YOLOv8 model, camera drivers, flashing the ESP32 firmware, first r…
Calibration
1–2 hours: mechanical calibration (arm lengths), homing calibration, vision calibration (checkerboard, pixel-to-mm mapp…
Programming
2 hours, intermediate: GCode basics and M-codes, a complete pick sequence, the Python serial API, YOLOv8 vision process…
Examples
Four complete, runnable projects: simple pick and place, vision-based colour sorting, conveyor tracking, and integratin…
Troubleshooting
Diagnosis and fixes for common hardware (motors, A4988 overheating, vacuum pump, suction), software (serial port, depen…
API
Complete command and API reference: GCode motion and M-codes, parameter units, Python serial and vision APIs, firmware …
| BOM | Bill of materials (Complete System) v1.0 |
|---|---|
| Datasheet | Full wiring diagram |
| Datasheet | ESP32 pinout |
The full source code (software, firmware, CAD files) is provided after purchasing the hardware kit. Email your order confirmation to service@nenpower.com and we will send you access. You will need to calibrate mechanical parameters if using custom hardware.
Typical precision is ±0.1mm with proper calibration, thanks to 16-microstep drivers and 4.5:1 gear ratio. Repeatability is excellent (~0.05mm). Absolute accuracy depends on calibration quality and mechanical tolerances.
Basic programming knowledge helps, but not required. Our documentation includes step-by-step tutorials from beginner to advanced. If you can install Python and follow instructions, you can get this running.
Yes! We provide labelImg tool for data annotation and complete instructions for YOLOv8 training. The Complete Solution kit includes one custom model training service from our team.
Primary support is Windows 10/11 (tested). Linux compatibility is good (Ubuntu 20.04+). macOS should work but is untested. All Python dependencies are cross-platform.
Complete pick-and-place cycle: 3-5 seconds depending on distance. Max speed is 100mm/s but actual throughput depends on object spacing, conveyor speed, and vision processing time (~100ms for YOLOv8).
Yes! CAD files (STEP format) are provided with your purchase. Common modifications: arm length changes, custom end effectors, or adding a 4th axis (rail). The kinematics solver parameters are configurable in firmware.
Hardware comes with a 12-month limited warranty covering manufacturing defects. You may return an item within 7 days of delivery; return shipping is paid by the buyer and the item must be unused and in its original packaging — see the Returns section below for the full terms. We also offer lifetime software support by email.
12-month limited warranty covering manufacturing defects. Consumables (suction cups, belts) and damage from modification are excluded.
Returns. You may return an item within 7 days of delivery for a refund.
EU, EEA and UK consumers also have a statutory right to withdraw within 14 days of delivery without giving a reason — see our Terms of Sale. Your statutory rights are not affected.
4-axis SCARA arm with ESP32 GCode controller — the same toolchain as our Delta robot, with a larger reach.